Closed-loop control
2-DOF PID with anti-windup and bumpless manual/auto, cascade loops, hysteresis, setpoint ramp/soak programs, PWM / time-proportional output, PT1 filter, differentiator, and a unit-delay (z⁻¹) node for closing feedback loops in-graph.
Every category, one palette
No add-on packs: Math, Logic, Control, Time, I/O, Variables, Views, Vision, Canvas, Spatial, Motion, Devices, Smart-home, Audio, Text, Diagnostics, Logging, HMI, plotting, inputs and reusable sub-networks — all in the box.
Real-time determinism
Dedicated RT process on a PREEMPT_RT kernel with CPU partitioning baked into the image and a native driver that takes the fieldbus NIC out of the Linux network stack entirely. Verified at 1 ms: sub-µs delivered jitter, <20 µs worst-case wake.
It benchmarks itself
Allocation-free latency histograms (p50/p90/p99/p99.9/max), two-point jitter, a stall-attribution journal and allocation tripwires ship in the product — live on every device, not a one-time lab result.
Dual-loop architecture
A hard real-time loop runs control at the set cycle; a separate ~60 Hz loop drives LED / visual output — both independently configurable, so rendering never disturbs control timing.
Live authoring
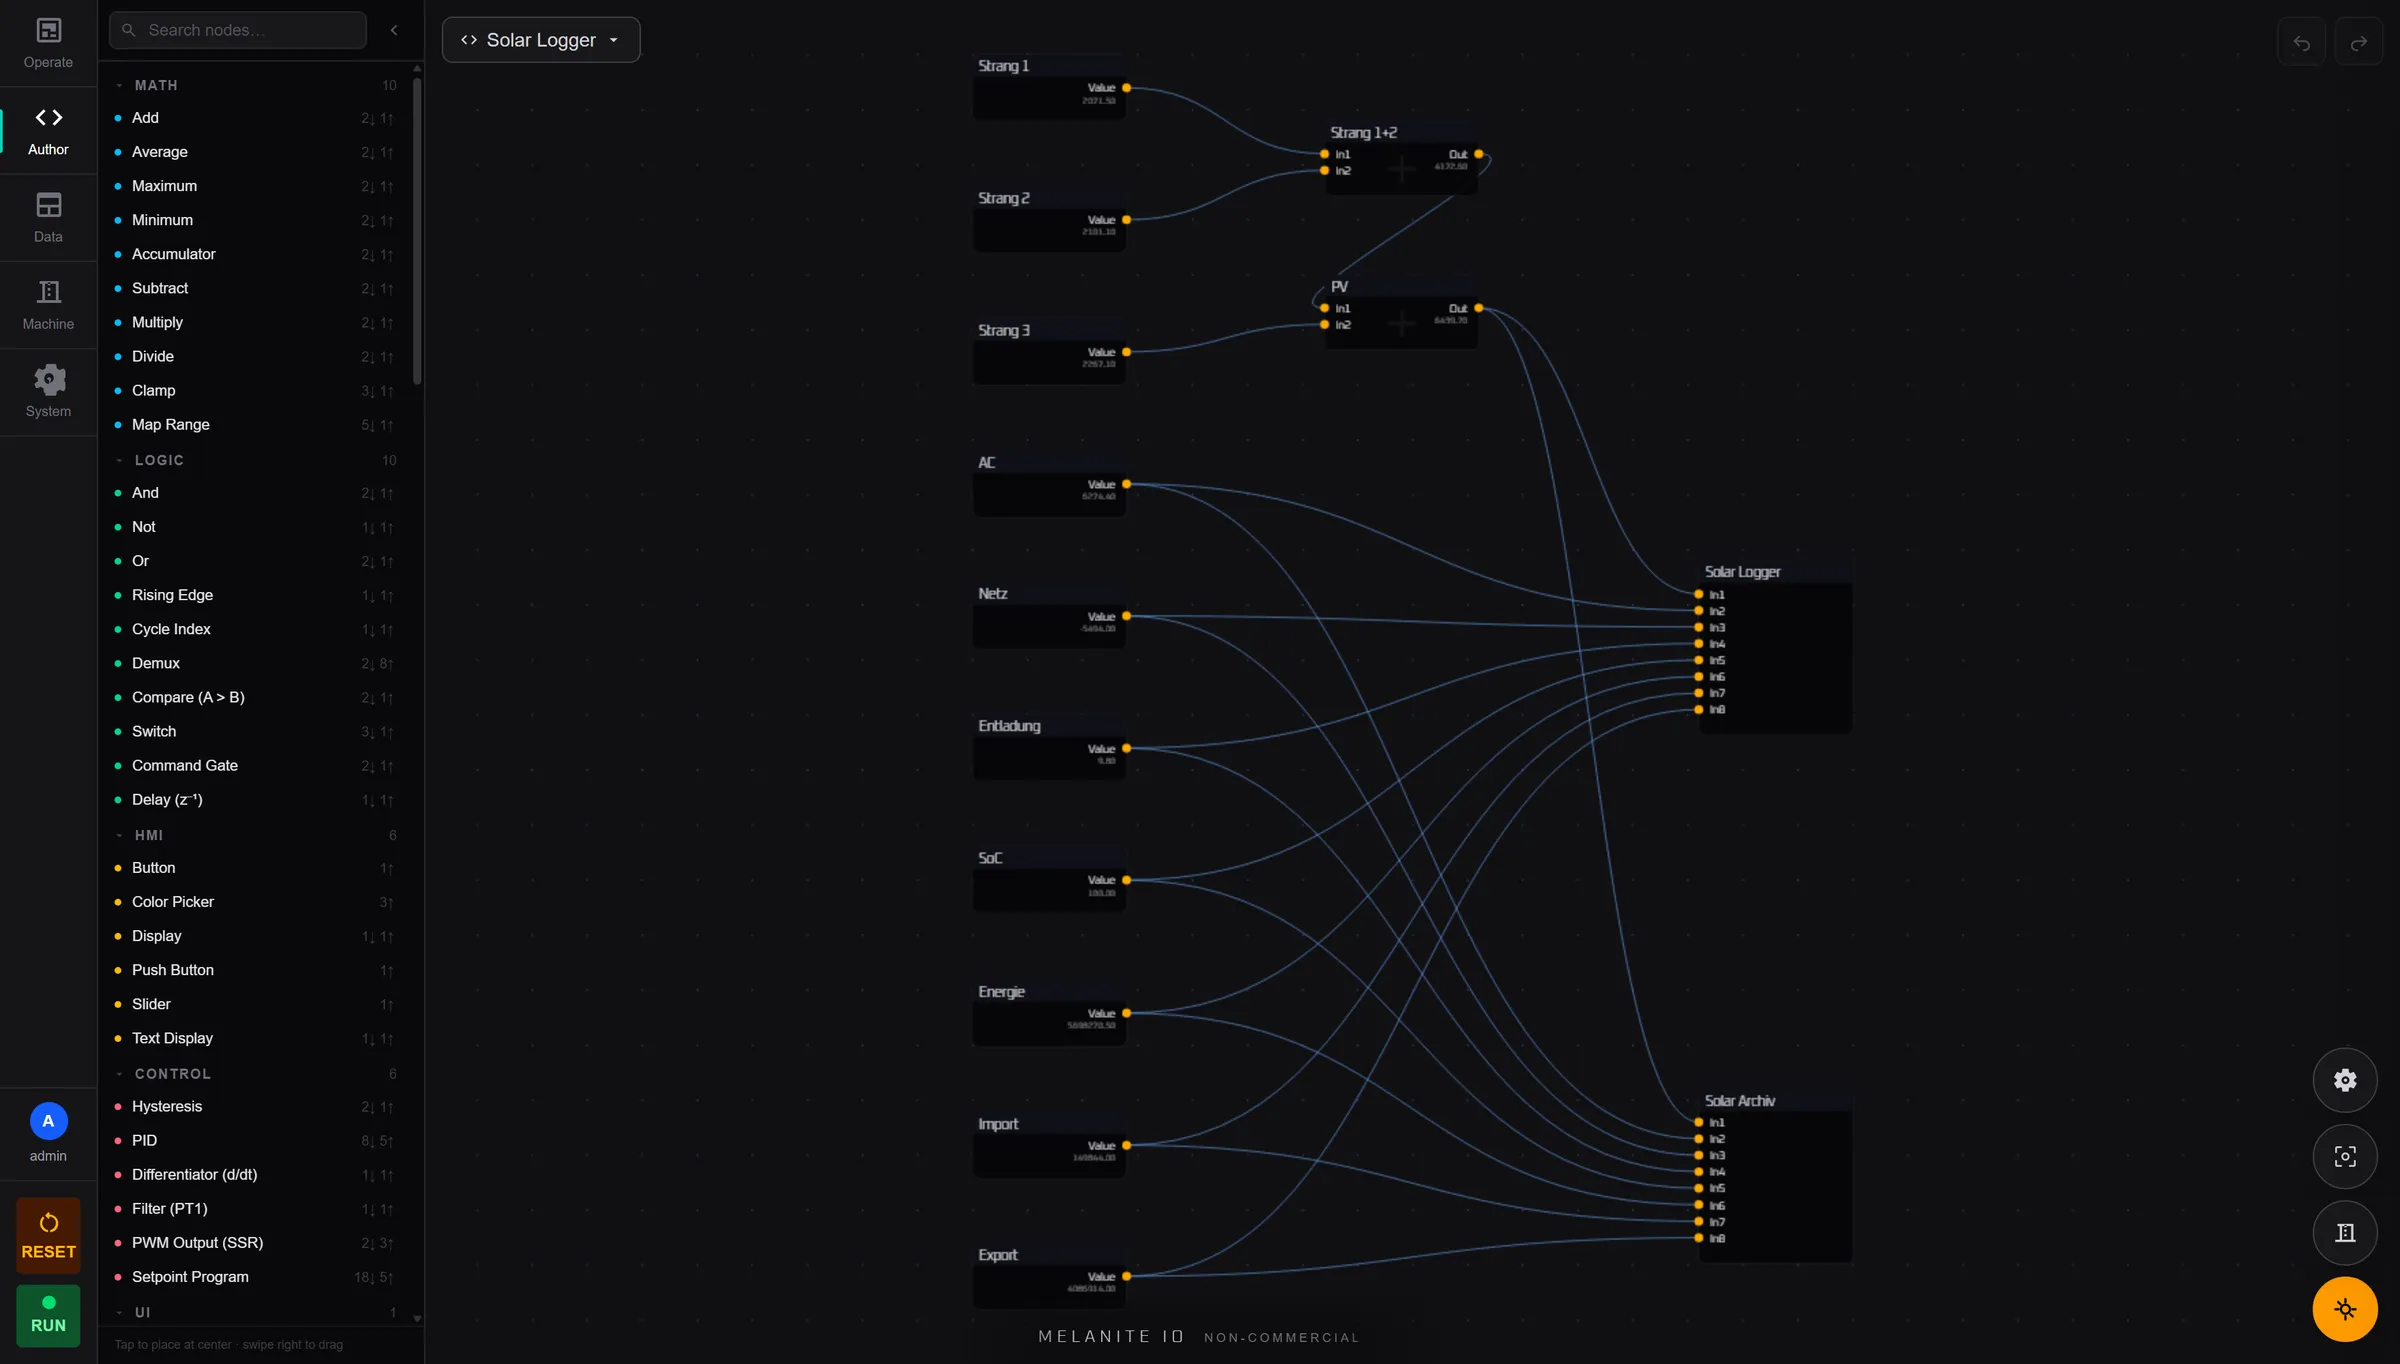
Edit the running graph in-browser — slider and parameter changes apply to the live process with no recompile or download. Per-network compile isolation means one broken network can't take the others down.
Function blocks & typed ports
Encapsulate a subgraph as a reusable, nestable sub-network. A two-family port type system (scalar values vs. reference values like views and images) rejects nonsensical wires at connect time, at zero real-time cost.
Undo, everywhere
Editor-wide history with Ctrl+Z / Ctrl+Shift+Z — and an entire AI-assistant turn collapses into a single undo step.